I’m Lorenzo, a PhD researcher working on robot learning and generative models for Physical AI.
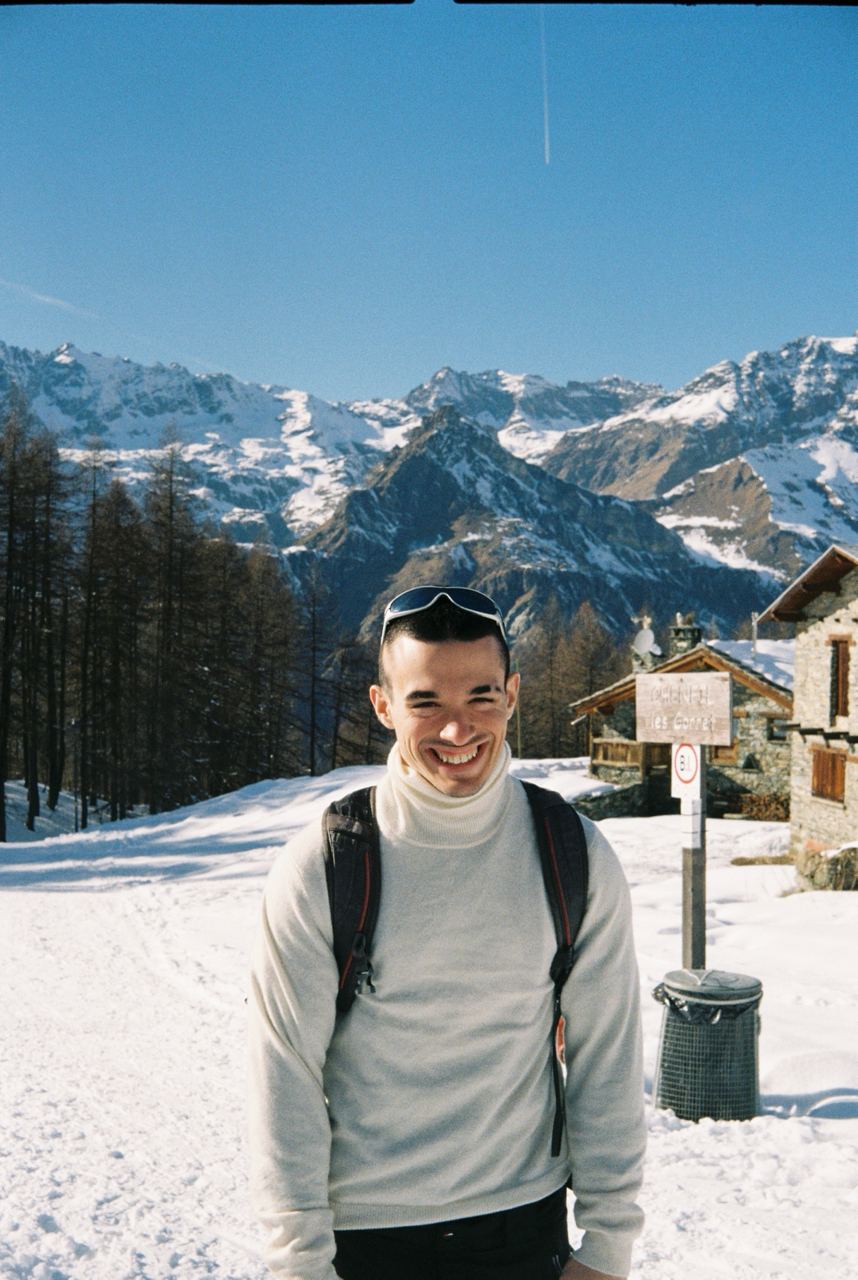
Enjoying the Italian Alps.
About my work
I am a PhD candidate in Computer Science at TU Dresden, working in the Translational Surgical Oncology group at NCT/DKFZ, led by Prof. Stefanie Speidel.
My research focuses on robot learning with generative models: learning multimodal distributions, remaining robust under distribution shifts at deployment time, and adapting behavior to test-time constraints. I combine imitation learning and reinforcement learning with experiments in simulation and on physical robots.
Autonomous surgical robotics is a central application of my PhD. Alongside developing learning algorithms, I build tools for collecting data, comparing policies, and deploying them on robots.
Before my PhD, I studied Machine Learning at KTH Royal Institute of Technology and worked in machine learning research and development at Ultramarin in Berlin.
We study how generative behavioral-cloning policies represent multimodal expert behavior. In latent-variable policies, posterior-prior regularization can erase action-mode information; preserving it shifts the challenge to deployment-time prior coverage. In action-space policies, smoothness limits the ability to represent many well-separated modes without sharp transitions or off-support bridges. Synthetic multimodal navigation and physical-robot bimodal manipulation experiments support these mechanisms, while deterministic regression remains competitive on standard robotic simulation benchmarks with limited conditional multimodality.
@misc{mazza2026understandingmultimodalitygenerativebehavioral,title={Understanding Multimodality in Generative Behavioral Cloning},author={Mazza, Lorenzo and Datres, Massimiliano and Rodriguez, Ariel and Bodenstedt, Sebastian and Kutyniok, Gitta and Speidel, Stefanie},year={2026},eprint={2605.22493},archiveprefix={arXiv},primaryclass={cs.LG},url={https://arxiv.org/abs/2605.22493},}
Supervised Mixture-of-Experts for Surgical Grasping and Retraction
Lorenzo Mazza, Ariel Rodriguez, Rayan Younis, and 6 more authors
In Robotics: Science and Systems, co-main author , 2026
A supervised Mixture-of-Experts architecture for imitation learning in surgical grasping and retraction. The approach transfers zero-shot to ex vivo tissue, with preliminary in vivo porcine evaluation.
@inproceedings{mazza2026supervised,title={Supervised Mixture-of-Experts for Surgical Grasping and Retraction},author={Mazza, Lorenzo and Rodriguez, Ariel and Younis, Rayan and Lelis, Martin and Hellig, Ortrun and Li, Chenpan and Bodenstedt, Sebastian and Wagner, Martin and Speidel, Stefanie},booktitle={Robotics: Science and Systems},year={2026},}
An Open-Source Robotics Research Platform for Autonomous Laparoscopic Surgery
Ariel Rodriguez, Lorenzo Mazza, Martin Lelis, and 4 more authors
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), accepted, co-main author , 2026
An open-source, robot-agnostic Remote-Center-of-Motion controller integrated into a ROS platform for teleoperation, demonstration recording, and autonomous laparoscopic policy deployment.
@inproceedings{rodriguez2026platform,title={An Open-Source Robotics Research Platform for Autonomous Laparoscopic Surgery},author={Rodriguez, Ariel and Mazza, Lorenzo and Lelis, Martin and Younis, Rayan and Bodenstedt, Sebastian and Wagner, Martin and Speidel, Stefanie},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},}
Open-H-Embodiment: A Large-Scale Dataset for Enabling Foundation Models in Medical Robotics
An open, multi-institution dataset of synchronized medical robotic video and kinematics for training and evaluating robot learning models. I contributed to the data collection pipeline and acquisition of 200 in vivo surgical trajectories.
@article{openh2026embodiment,title={Open-H-Embodiment: A Large-Scale Dataset for Enabling Foundation Models in Medical Robotics},author={{Open-H-Embodiment Consortium}},journal={arXiv preprint arXiv:2604.21017},year={2026},}
LAR-MoE: Latent-Aligned Routing for Mixture of Experts in Robotic Imitation Learning
Ariel Rodriguez, Chenpan Li, Lorenzo Mazza, and 5 more authors
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), accepted, coauthor , 2026
A two-stage imitation-learning framework that discovers skills without phase labels and uses the learned latent structure to guide Mixture-of-Experts routing. Evaluation on LIBERO and surgical grasping and retraction shows structured expert specialization and zero-shot transfer to ex vivo porcine tissue.
@misc{rodriguez2026larmoelatentalignedroutingmixture,title={LAR-MoE: Latent-Aligned Routing for Mixture of Experts in Robotic Imitation Learning},author={Rodriguez, Ariel and Li, Chenpan and Mazza, Lorenzo and Younis, Rayan and Hellig, Ortrun and Bodenstedt, Sebastian and Wagner, Martin and Speidel, Stefanie},year={2026},eprint={2603.08476},archiveprefix={arXiv},primaryclass={cs.RO},url={https://arxiv.org/abs/2603.08476},}